Future Direction-Aware Flocking via Velocity Prediction
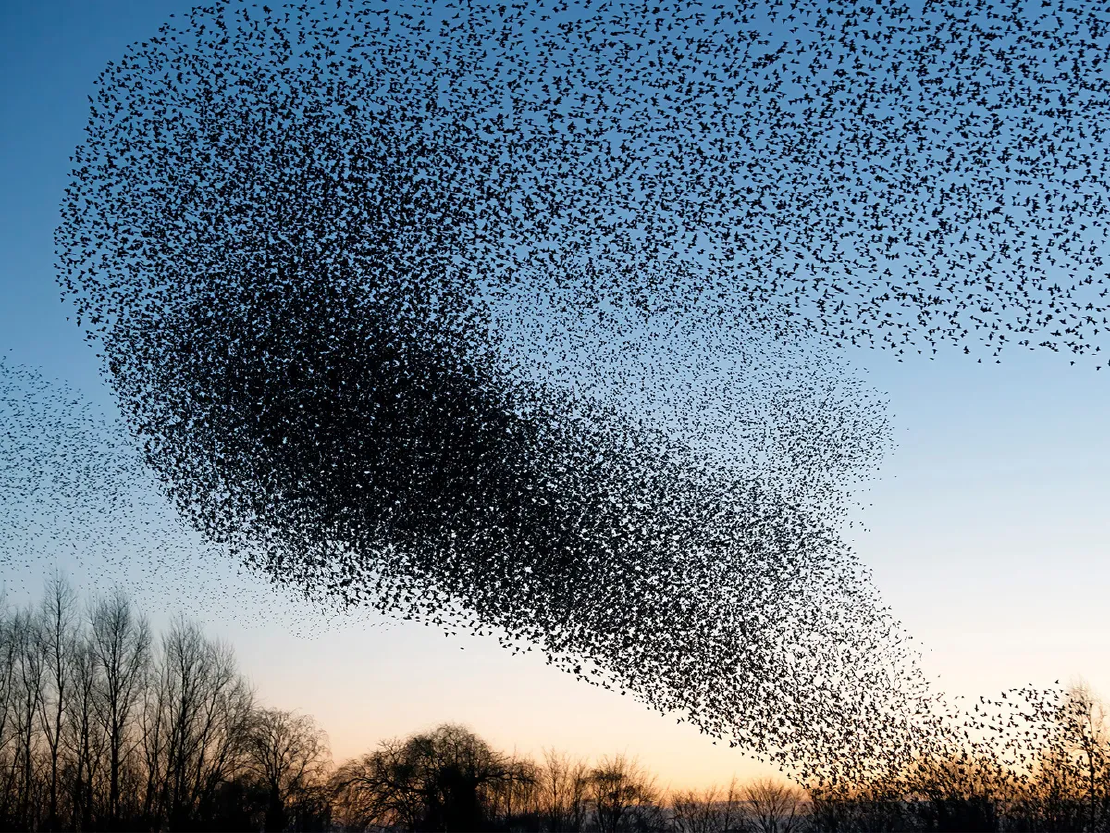
This paper looks at how robot swarms can move more smoothly by not only reacting to what nearby robots are doing now, but also by briefly predicting where they are about to move next. The idea is inspired by birds and drones, where small body movements often signal a turn before it actually happens.
24-Mar-2026
Read more