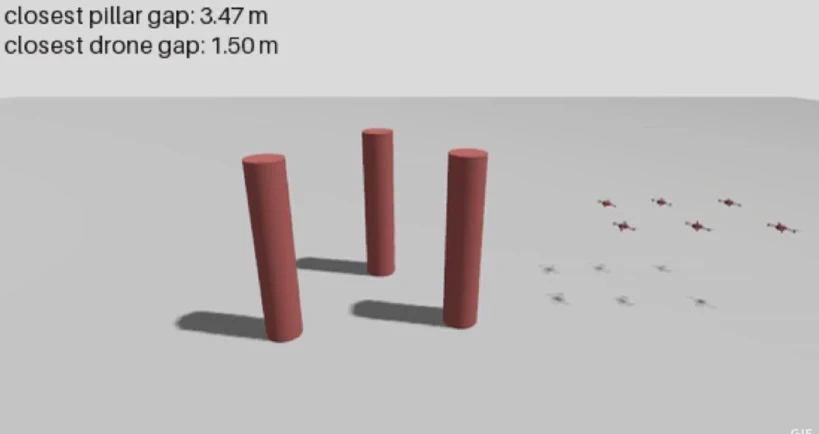
An independent developer has released an open-source simulation demonstrating six drones maintaining formation while navigating obstacles without a central flight controller.
Flockwork implements decentralised swarm control in C++ using ROS 2 Jazzy and Gazebo Harmonic. Each drone independently calculates its movement using neighbouring positions, formation offsets and obstacle-avoidance constraints. In the demonstration, six simulated drones separate to navigate around three pillars under simulated wind disturbances, then reform their grid at the destination. The developer explains that the controller evolved from conventional Boids flocking rules into displacement-based formation consensus to reduce oscillations.
https://www.reddit.com/r/ROS/comments/1x1uheb/decentralized_drone_swarm_flying_in_formation/