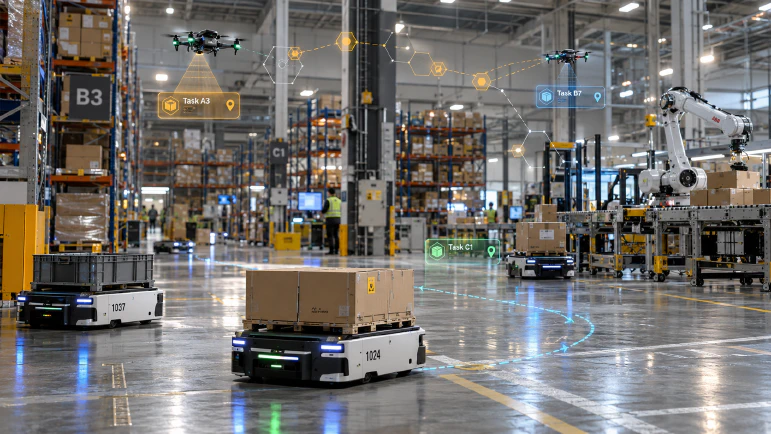
A new bee-inspired coordination algorithm allows robot swarms to allocate changing tasks without central management or synchronised clocks.
Researchers developed an Improved Artificial Bee Colony algorithm that combines local probabilistic recruitment, finite-state machines and quorum-based congestion avoidance. Each robot progresses through eight operational states while responding to nearby tasks and other participants. An adaptive motivation-decay mechanism balances persistence against responsiveness, reducing the risk of robots becoming trapped in unsuitable assignments or repeatedly switching tasks. Monte Carlo simulations involving changing task arrivals and unexpected robot failures showed improvements in task completion, energy efficiency and communication overhead against comparison algorithms.