Researchers have demonstrated a decentralised security mechanism that allows cooperating robots to reject malicious information while continuing to trust legitimate neighbours.
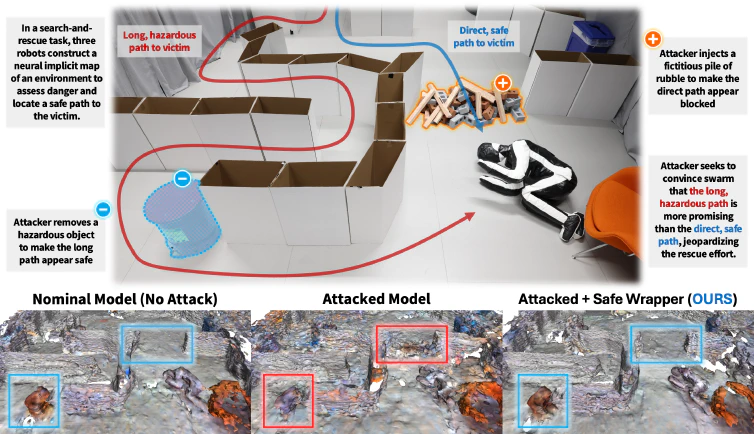
The Safe Wrapper algorithm operates independently on each robot, examining streams of locally collected trust measurements associated with incoming communication links. Statistical confidence sequences determine when a neighbour’s information can safely be incorporated into collective decisions. Hardware experiments involved eight GoPiGo robots performing distributed heading consensus under a Sybil attack and three LoCoBots constructing a shared neural map while an attacker injected misleading environmental information. Additional simulations investigated scalability to hundreds of robots.