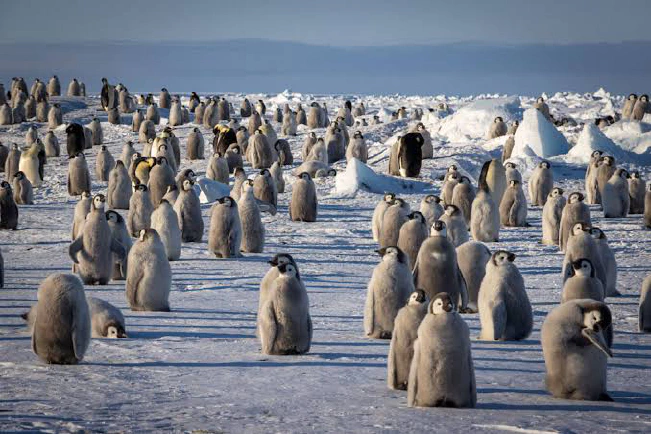
A simulated lunar robot swarm has independently developed two cooperative survival behaviours resembling those of emperor penguins.
Researchers trained a shared reinforcement-learning policy for twenty robots using only the temperature of the five coldest members as the final reward. Without instructions about formations or sheltering, robots gathered into protective clusters and circulated between exposed edges and warmer interiors. The resulting strategy required 37% less stored heat than a stationary huddle and transferred to forty robots without retraining. These are simulation findings, not evidence of an operational lunar deployment.