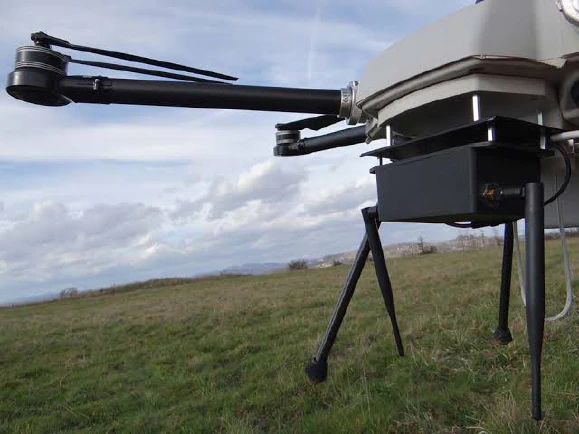
Researchers have developed a decentralised control framework in which autonomous drones communicate selectively rather than continuously.
Each UAV uses locally available information and a lightweight neural predictor to estimate when changes in its control state justify transmitting an update. Dynamic event-triggered communication reduces unnecessary exchanges while adaptive control accommodates uncertain and changing flight dynamics. Numerical experiments reported communication reductions of 45.5% and 95.1% across two control channels while maintaining bounded system behaviour. The results are simulation-based, not evidence of an operational drone deployment.